Motivation
•
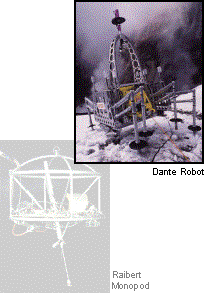
Statically-stable robots
•
Robust by maintaining
at least three legs on
the ground
•
Limited speed
Intro