
| “Simple” Model |
| K, B, qnom |

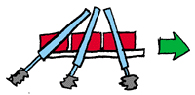
| k, b, lnom |
| Symmetry
assumption |
| Full 3D model |
| Planar model |
|
|
|
|
|
|
|
|
|
|
|
|
|
| • | Body
has 3 planar degrees of freedom |
|||||||||||
| – | x, z,
theta |
|||||||||||
| – | mass,
inertia |
|||||||||||
| • | 3
massless legs (per tripod) |
|||||||||||
| – | rotating
hip joint - damped torsional spring |
|||||||||||
| – | prismatic
leg joint - damped linear spring |
|||||||||||
| – | 6
parameters per leg |
|||||||||||
| 18
parameters to tune - TOO MANY! |
||||||||||||
| Intro |
| Biomimesis |
| Design |
| Analysis |
| Conclusions |